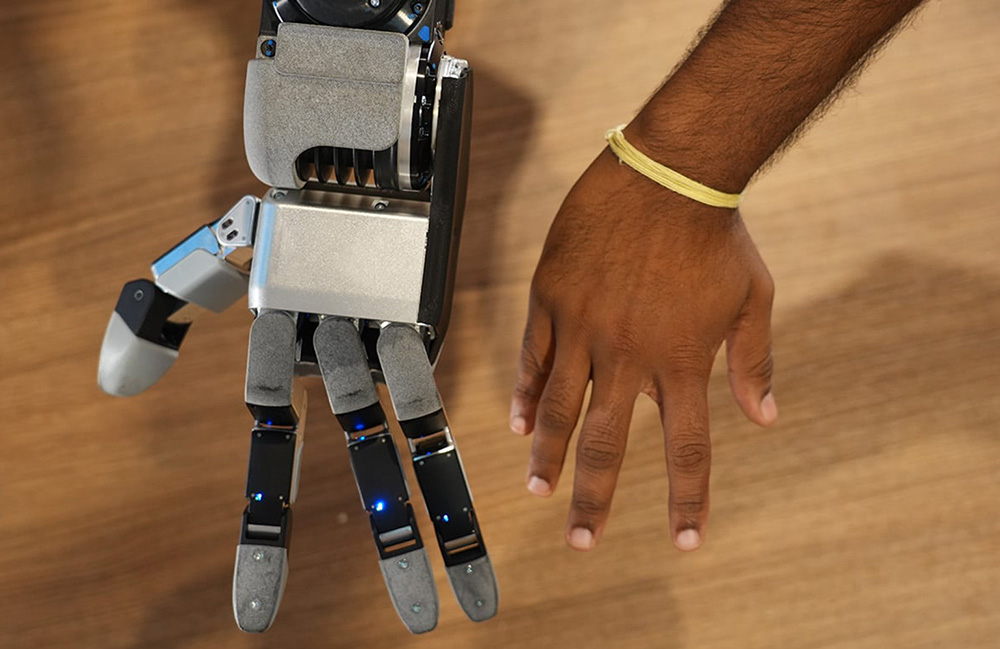
Boston Dynamics said its new hand is still capable of handling over 100 lb. | Source: Boston Dynamics
Last week, Boston Dynamics Inc. gave a look at its new humanoid robot hand. The four-fingered hand has 13 degrees of freedom, or DoF, and is directly actuated. The company said it designed it for mass manufacturing.
Lots of things immediately stand out about the hand. Notably, Boston Dynamics has dropped the pinky finger and reduced the size of the gripper. Less obviously, the company said it built the new hand for high-fidelity simulation to enable sim-to-real reinforcement learning (RL).
To learn more about the new hand, The Robot Report spoke with Alberto Rodriguez, the director of robot behavior for Atlas at Boston Dynamics.
Rodriguez: Having a product roadmap for Atlas has been a key enabler when it came to making hard decisions like what is the right level of complexity that we should be packing into a hand and navigating its design tradeoff between dexterity, strength, ruggedness, cost, reparability, and sensing.
We have learned things from the design of Atlas’ body. There are things like simplicity, modularity, and actuator maturity that make sense in theory, but over time, you start appreciating the huge impact they have in the velocity you can move.
A reliable robot allows you to capture data faster, run more experiments, and take bets at early deployments. Modularity allows you to focus with more energy on a smaller number of things that you need to get right.
Source link