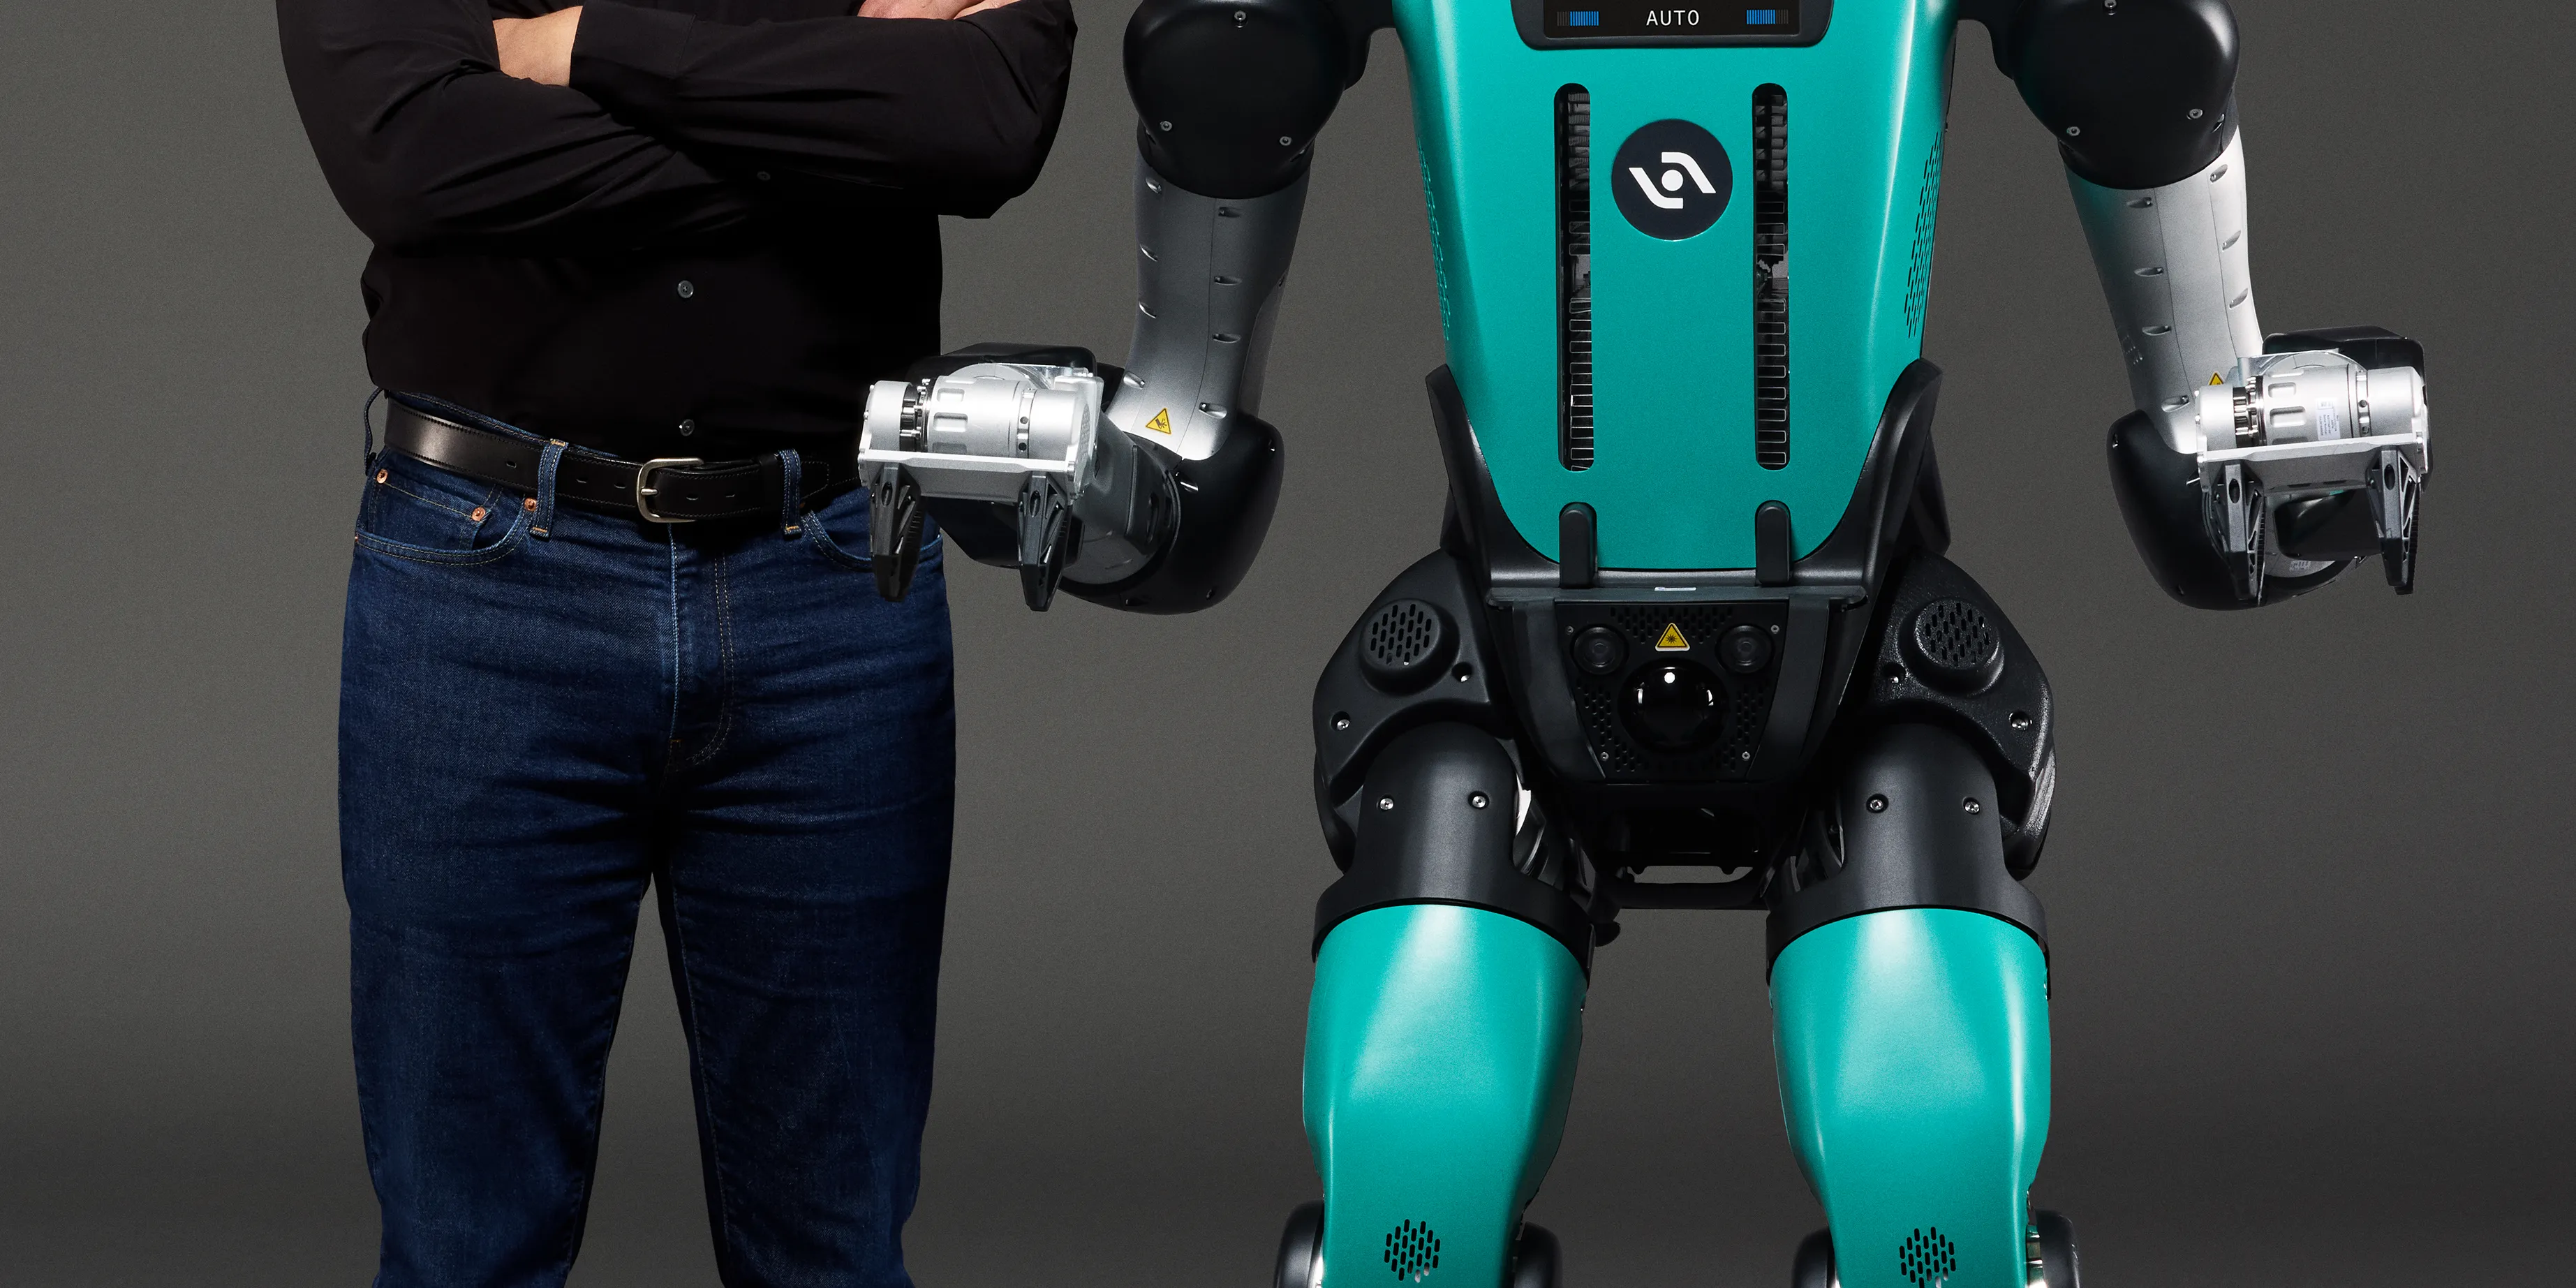
Agility Robotics, the company I cofounded out of my robotics lab at Oregon State University in 2015, has just launched Digit 5. It’s designed to be the first humanoid robot that can safely and economically do useful work at scale, allowing us to bring tens of thousands of humanoid workers into the real world. Engineered to lift 23-kilogram bins onto high shelves and with a battery that can run for 90 minutes on a 9-minute charge, Digit 5’s goal is to handle heavy warehouse tasks shift after shift, filling the need for labor in jobs that are too physically stressful or too dull for humans to want to do.
Digit 5 is what Agility has been working toward for over a decade. But the robot is heavy and bulky, lacking the graceful natural motion of its predecessors, and it’s farther than I thought possible from the robot I dreamed of building when I started this company. To deliver a useful commercial product, Agility has taken a path that is very different from what I first imagined.
My dream has always been to build robots that combine locomotion and manipulation to move through the world and interact with it as people do. I seek a mastery of motion, achieved through devices designed to navigate the constraints of physics with elegance. When I started the Dynamic Robotics Laboratory at Oregon State in 2008, we began with a theory derived from decades of work in biomechanics: that a simple “spring-mass” model (a body supported by legs that act like springs) should be able to reproduce every known walking and running gait found in animals.
Source link