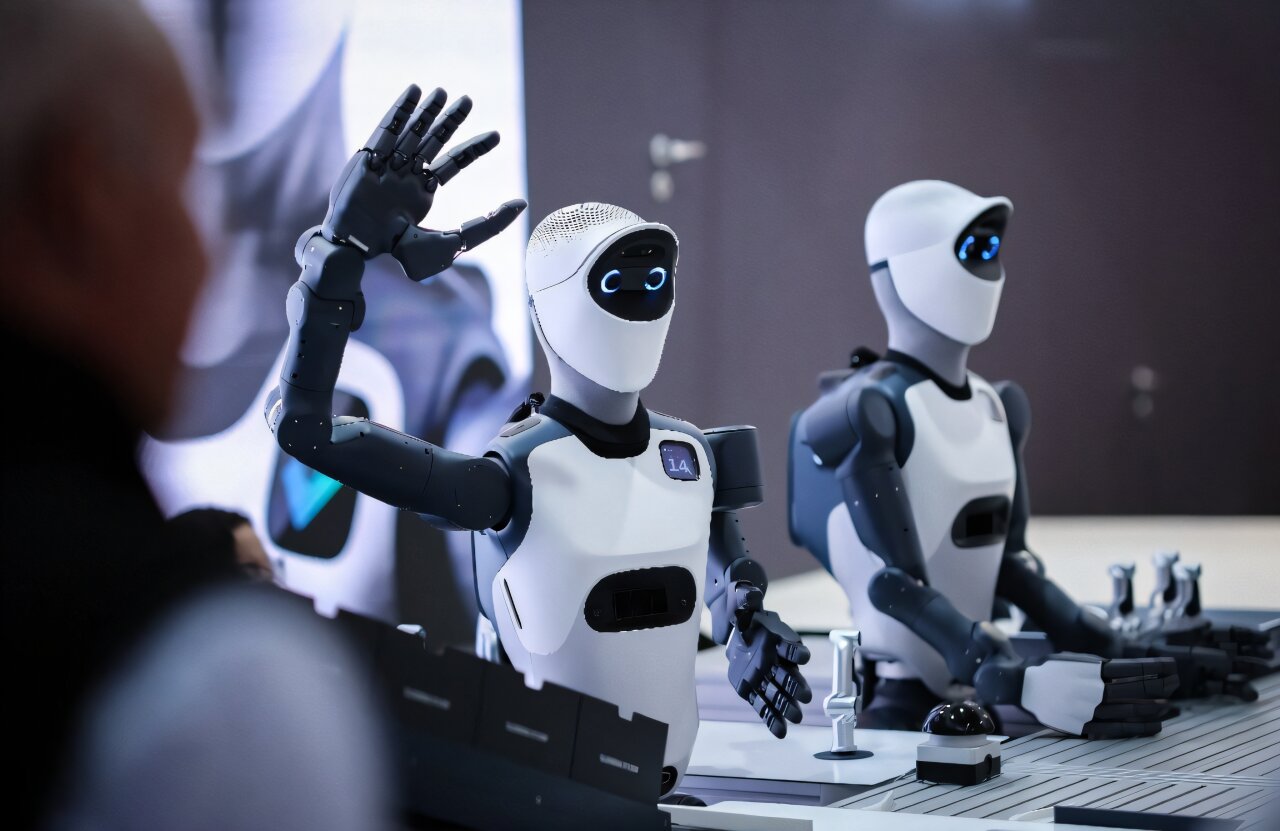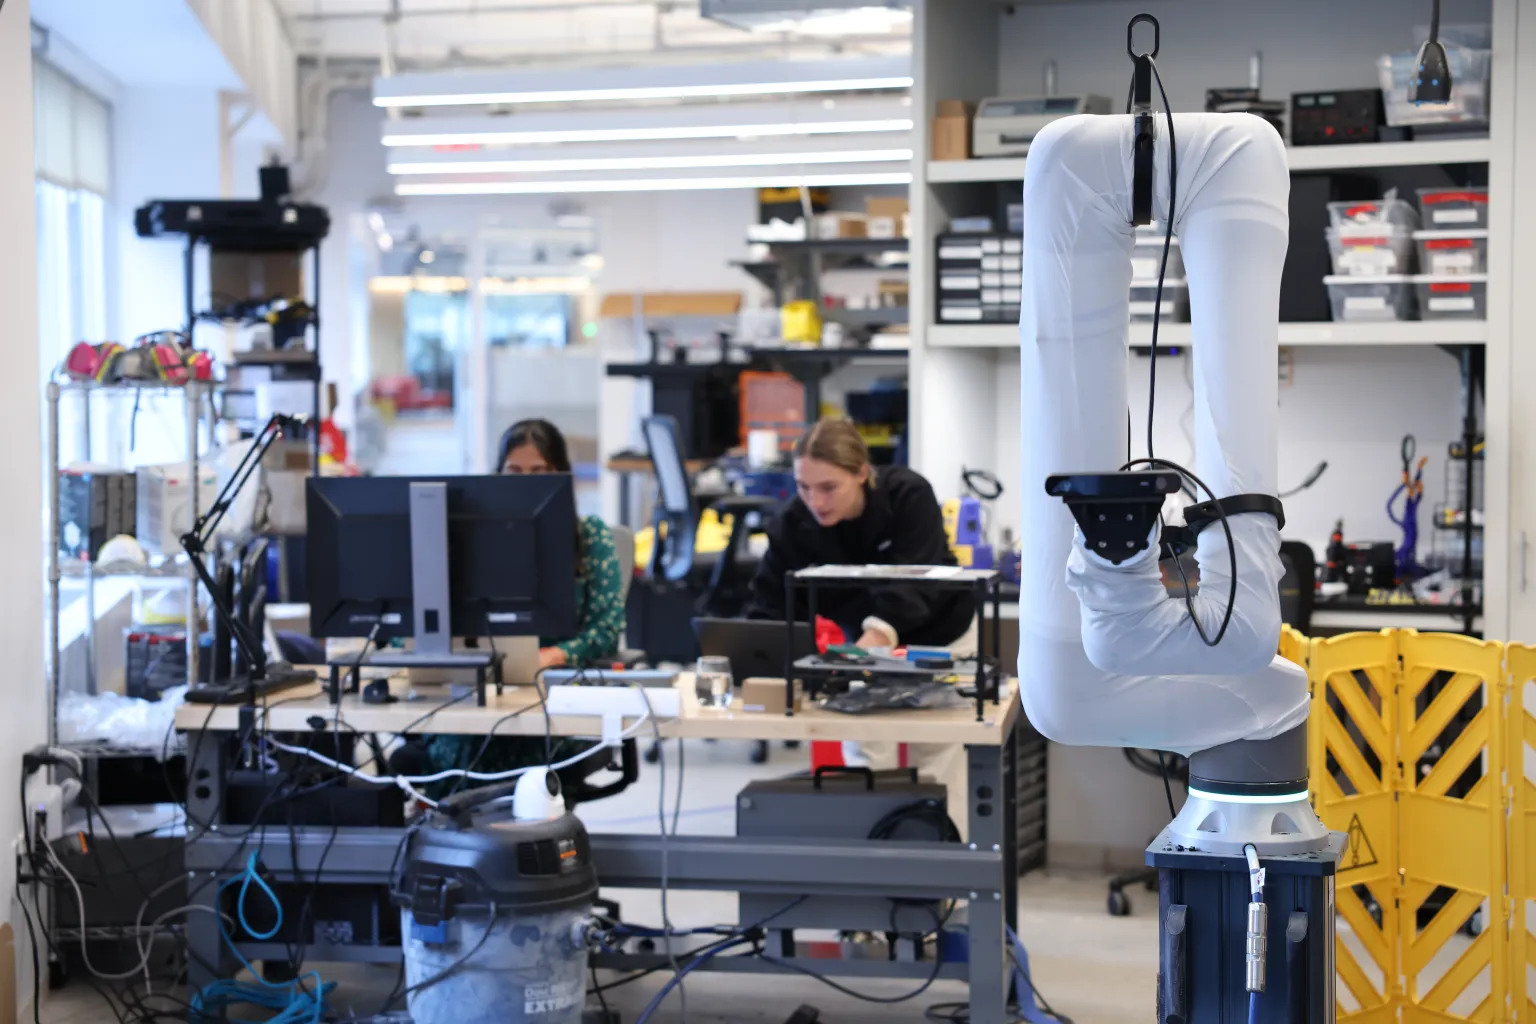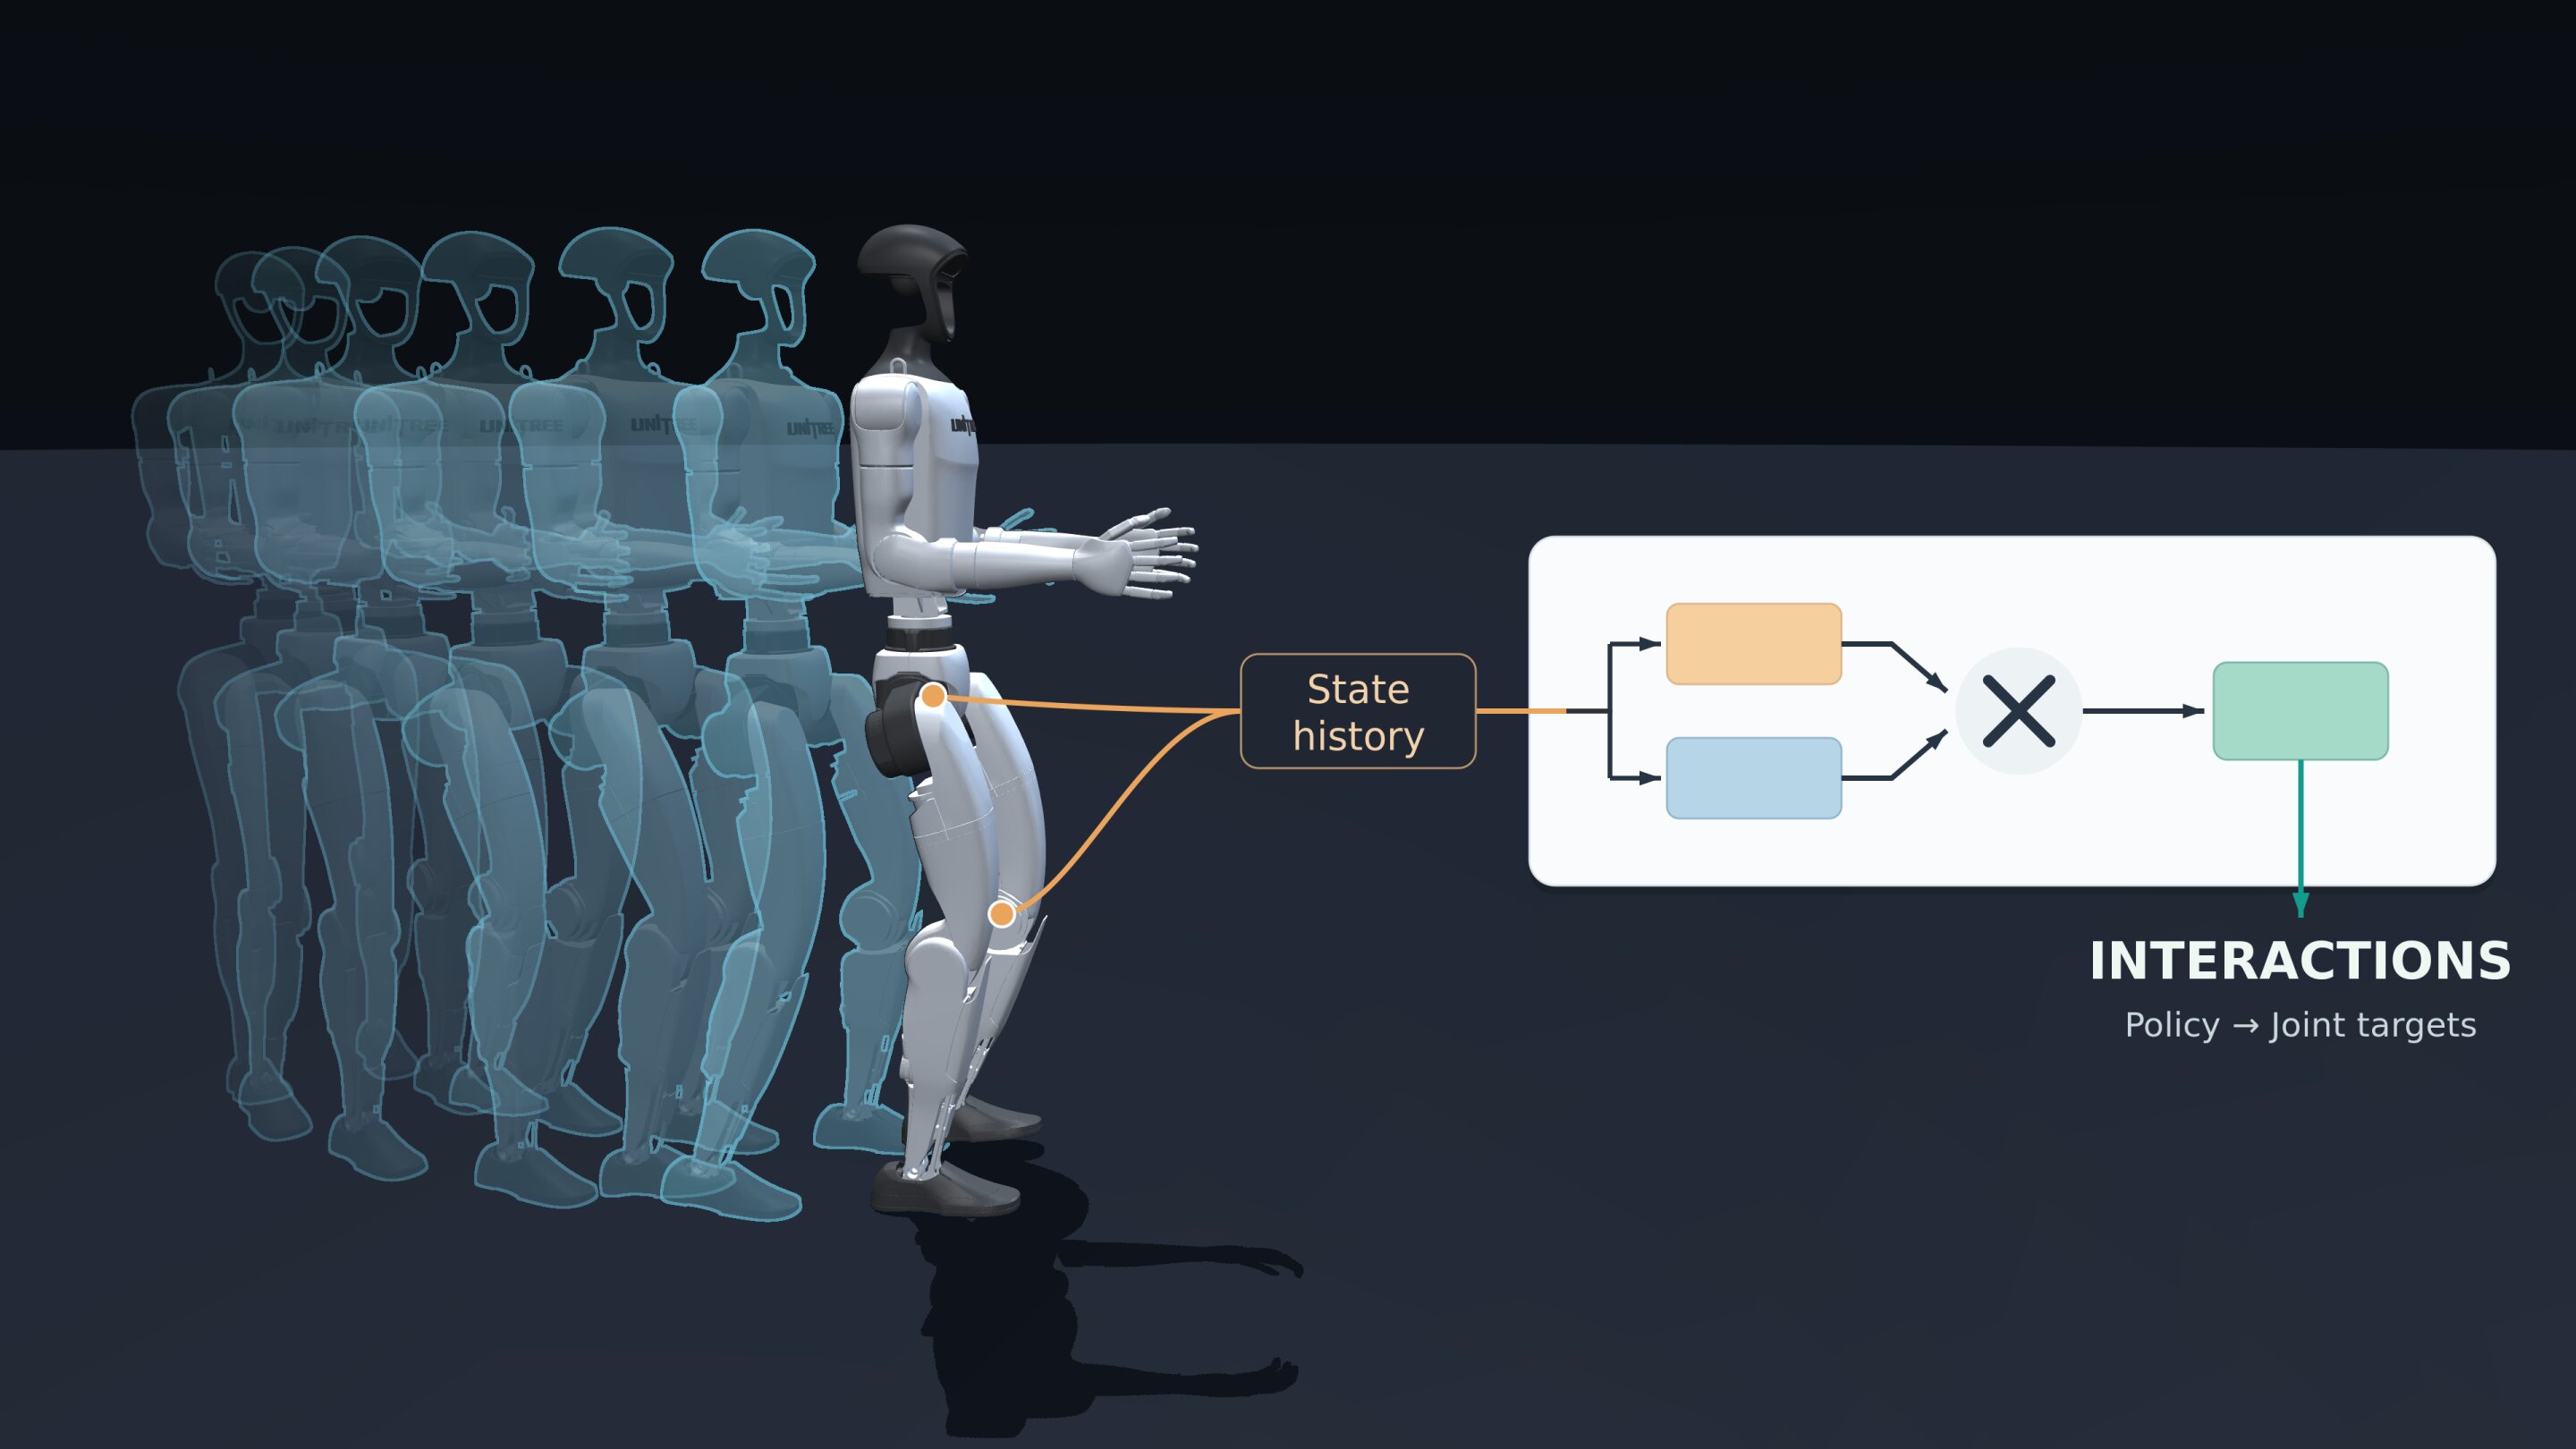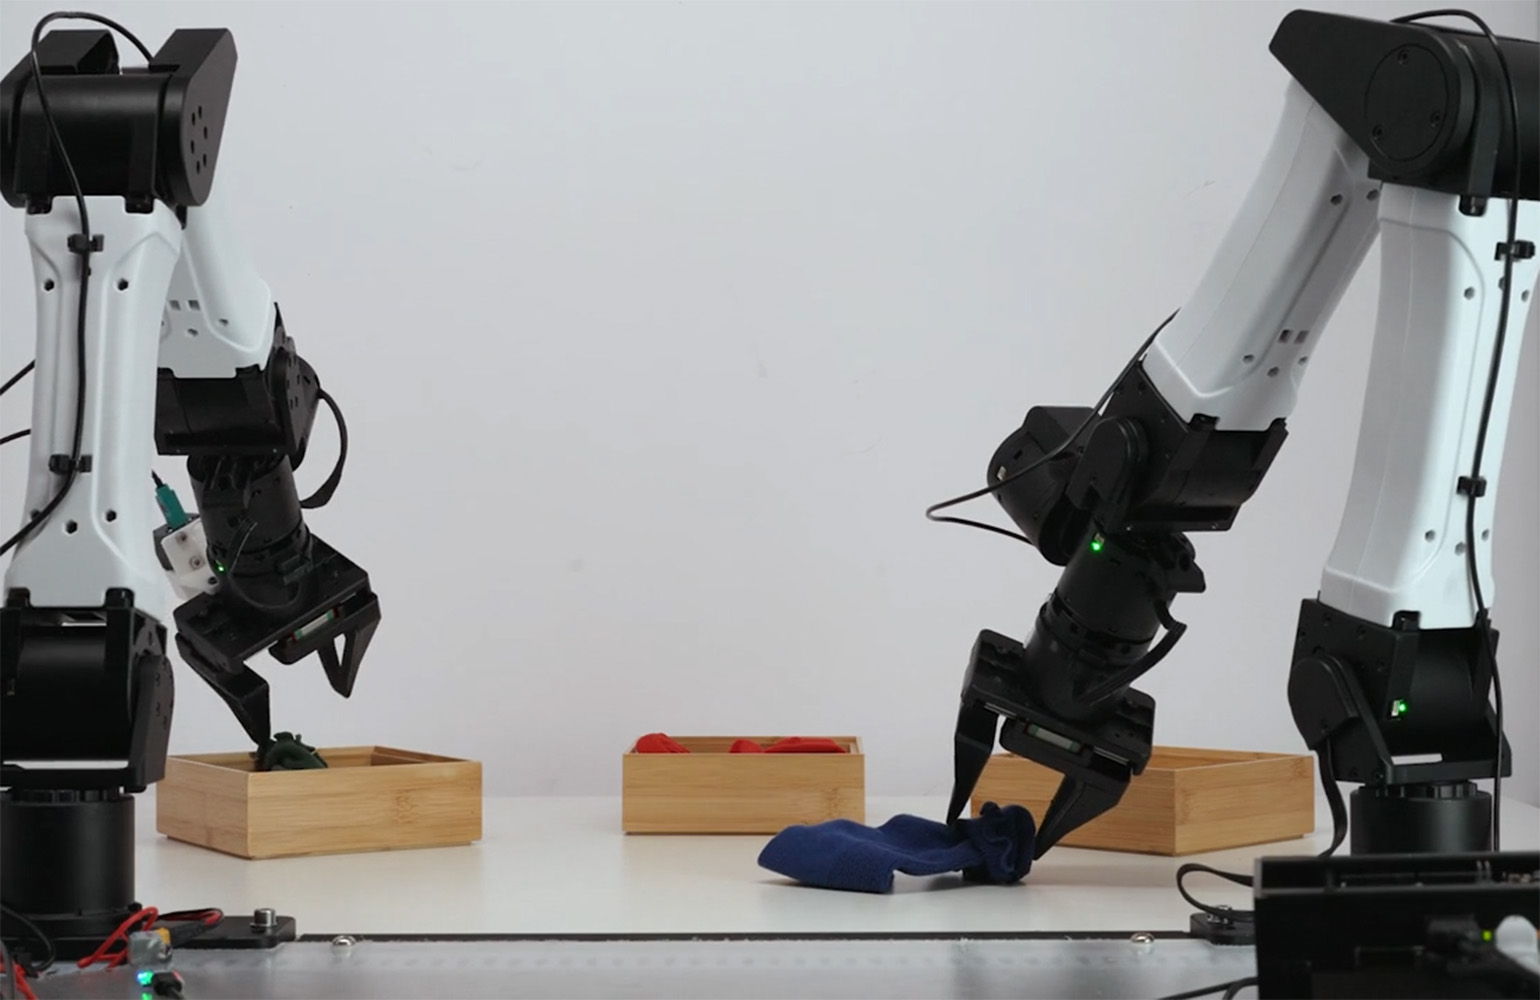
Praxis-1 builds on Runway’s work as a founding member of the Cosmos Coalition, advancing open world models for physical AI. | Source: Runway
Runway AI Inc. yesterday released Praxis-1, its world action model for robotics. The model is now available to developers with open weights under the Apache 2.0 license.
Runway first announced Praxis-1 in September with launch partners including Noble Machines, Standard Bots, and Ultra. Since then, these companies have been running the model on their own hardware, including a legged humanoid, a six-axis industrial arm, and a dual-arm warehouse robot.
“A strong base model goes a long way. Earlier, with Noble Machines, our previous model needed a lot of training to learn their warehouse task: picking up wooden planks one at a time and placing them in a container,” Andy Chen, the head of robotics at Runway, told The Robot Report. “Praxis-1, built with more compute and data, learned it from half an hour of examples and got it right 15 times out of 15. Then we gave it a messy pile of planks it had never seen to clear into bins, and it cleared the whole pile six times out of 10.”
“Iterating on feedback from partners makes our models better,” he continued. “Today, Praxis-1 is the top-ranked world action model on NVIDIA’s RoboLab leaderboard, and the top-ranked open-source, end-to-end policy.”
Praxis-1 is available on GitHub , on Hugging Face with native LeRobot support , and in vLLM-Omni, with hosted inference on Reactor .
Source link