This article has been reviewed according to Science X's editorial process and policies. Editors have highlighted the following attributes while ensuring the content's credibility:
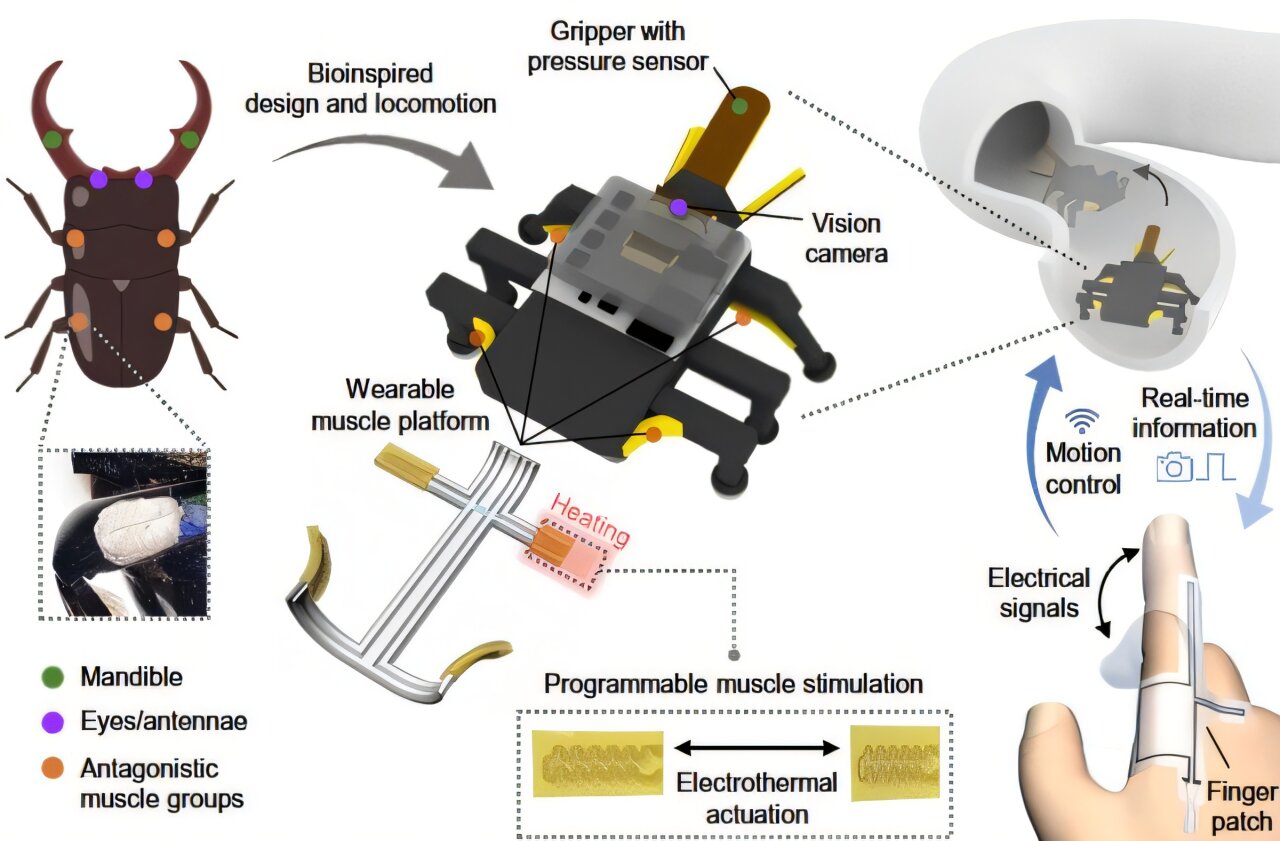
Researchers have developed a technology that lets a user move a small robot by bending and straightening a finger. The user can also pick up and move objects while checking the images and contact information that the robot sends back.
The system combines artificial muscles, a camera and tactile sensors in a small soft robot modeled on a beetle. It is expected to be used in remote tasks, such as inspecting narrow spaces that are difficult for people to reach and retrieving small objects.
A research team led by Professor Sang Ouk Kim from the KAIST Department of Materials Science and Engineering has developed a small soft robot called "BeetleBot." The team worked with the research groups of professor Wei Gao at the California Institute of Technology (Caltech) and professor Hirotaka Sato at NTU.
When people grasp an object, they use their eyes to find where it is and the sensation in their fingertips to check the contact. A robot that adjusts its work to its surroundings also needs its movement and sensing functions to be connected.
Soft robots are built from soft, deformable materials. In these robots, however, actuation, sensing and control are often built as separate parts or depend on complex devices. This has made it difficult to integrate several functions into a small robot.
The researchers designed the robot to walk and grip objects using artificial muscles that contract in a similar way to biological muscles.
Source link