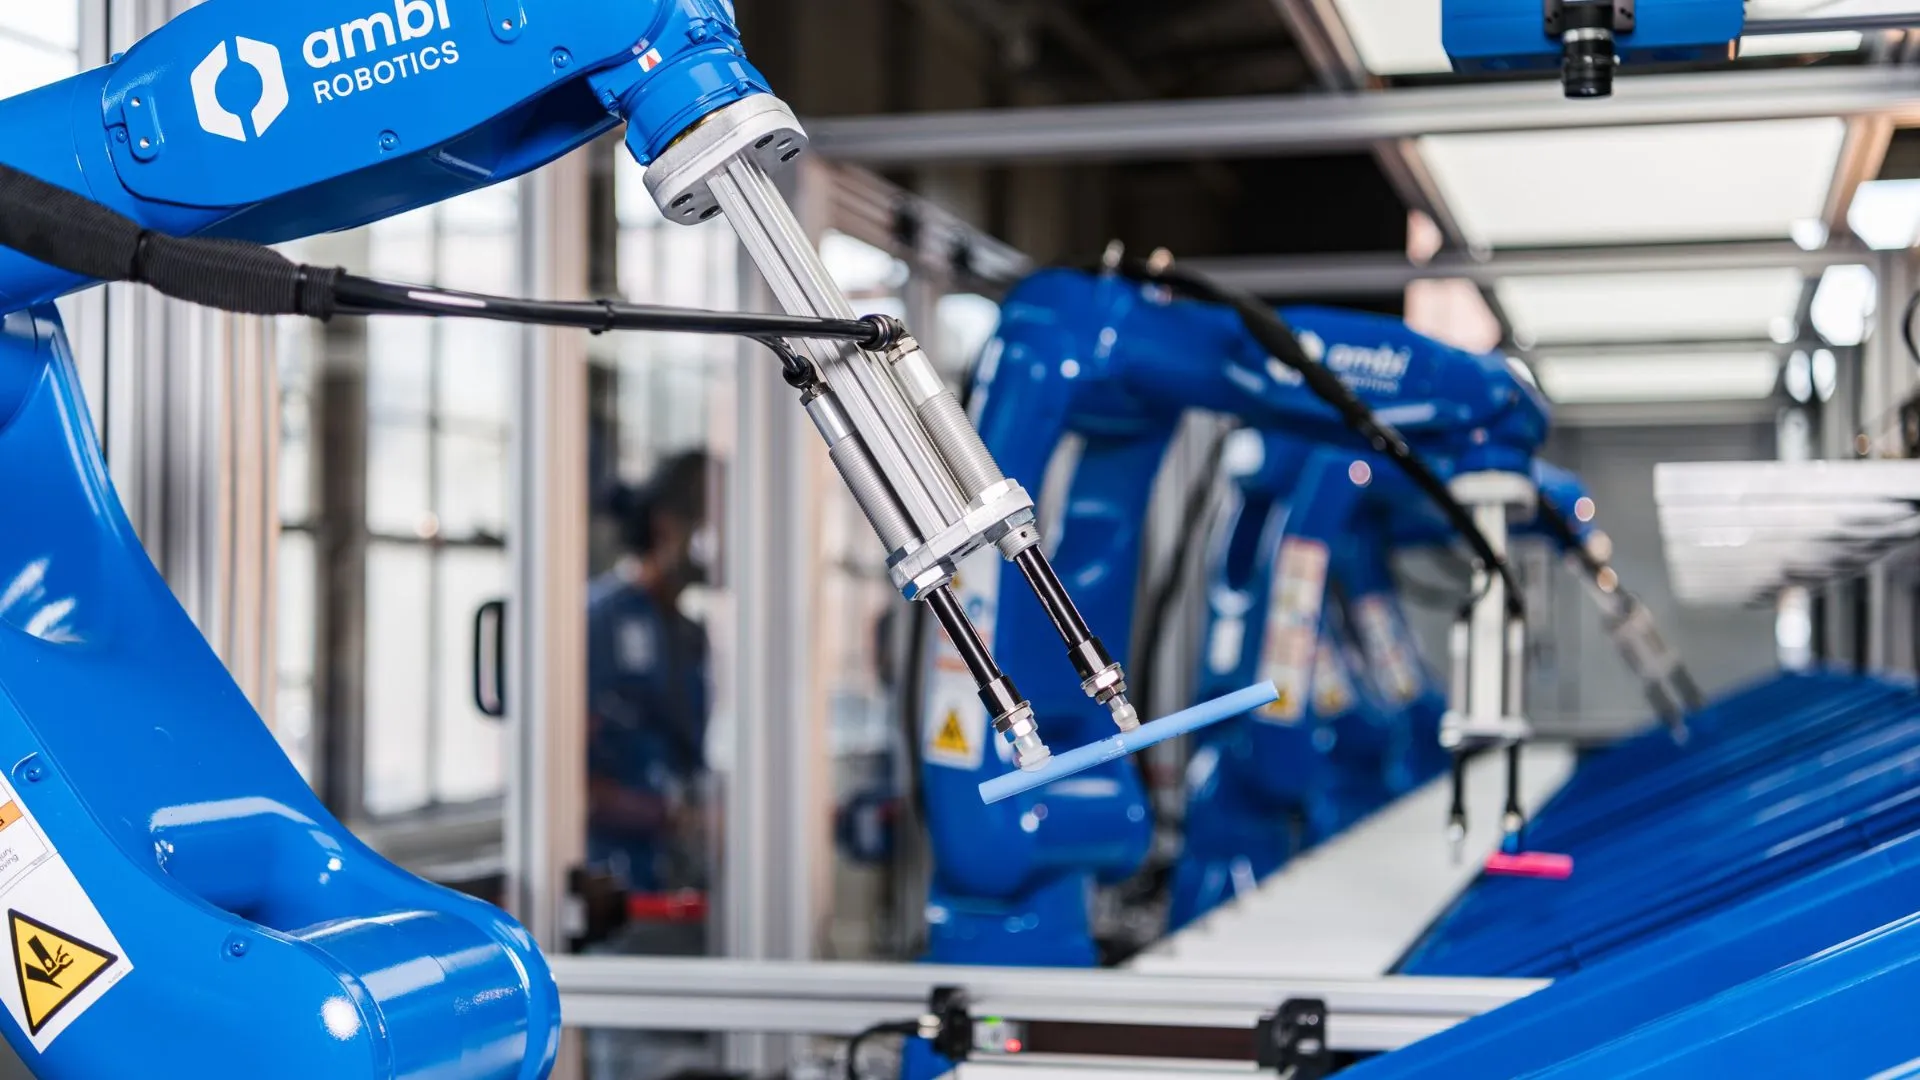
UC Berkeley researchers have developed an AI-driven approach that could significantly accelerate how robots are programmed and trained for real-world tasks. Called agentic robotics, the approach uses teams of AI agents to generate robot-control programs, test them in simulated environments, and refine their performance.
The method could reduce the need for extensive training data and manual engineering, two major challenges that have slowed the development of capable robots.
Early trials have demonstrated improvements in robotic task performance, pointing to potential applications in industrial automation and warehouse operations.
The new approach to robotic programming combines agentic AI, physics-based simulations, and modular control systems to help robots improve their performance without relying on enormous training datasets.
Called agentic robotics, the approach allows teams of AI agents to generate robot-control programs, test them in simulated environments, identify failures, and revise their code before deploying it on physical machines.
The technology could address two longstanding challenges in robotics: the extensive engineering required to program robot behaviors and the large volumes of real-world data needed to train robots through imitation learning.
Traditionally, roboticists have relied on two broad approaches. Model-based robotics involves engineers manually programming how machines perceive objects, plan movements, and control their actions. Model-free robotics uses demonstrations and imitation learning to teach machines how to perform tasks. While the former requires considerable engineering effort, the latter demands extensive datasets and lengthy training periods.
Agentic robotics seeks to combine the advantages of these methods while reducing their limitations. The approach uses a framework called Graph-as-Policy, which divides complex robotic tasks into smaller, reusable skills.
Source link