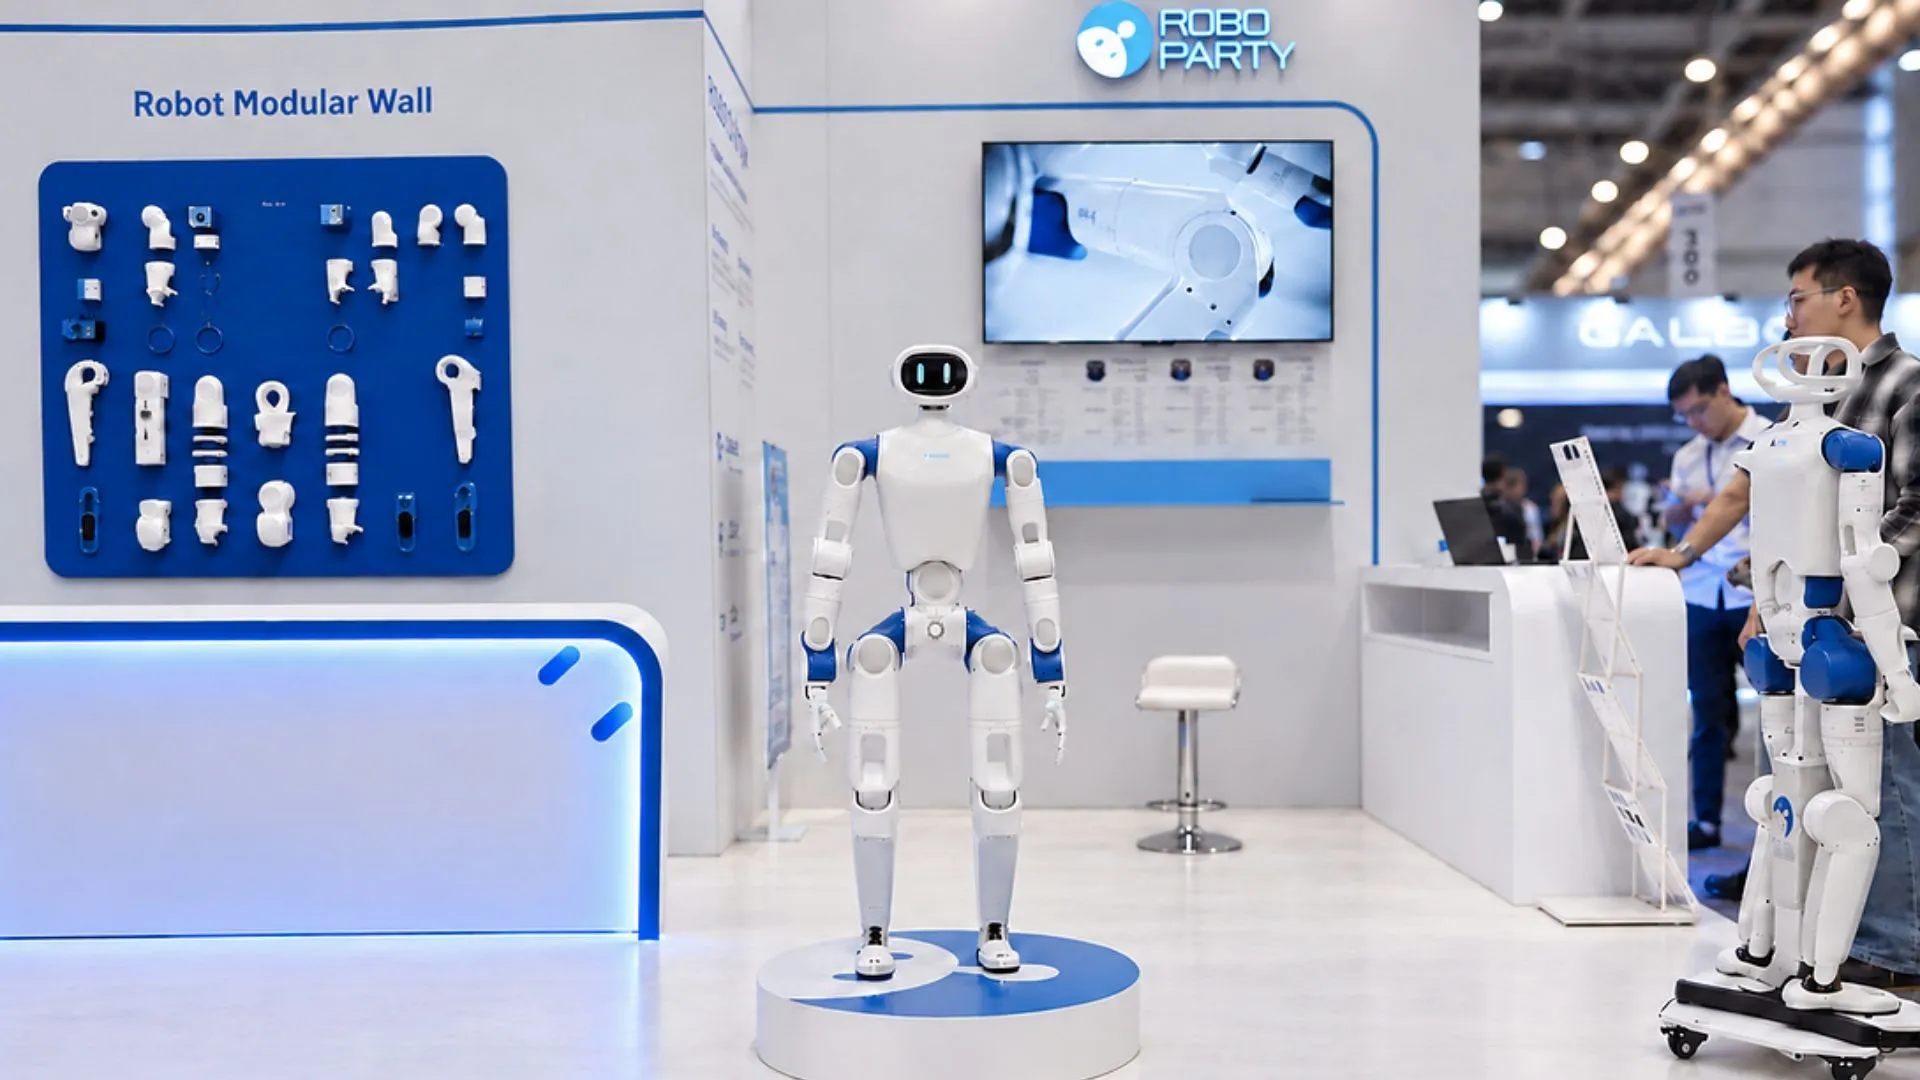
A Pittsburgh-based firm has unveiled its high-performance open source humanoid robot. Called RP1 (ROBOTO 01), the robot was publicly unveiled at at IROS 2026, marking the robot’s global debut.
The company positions RP1 as the world’s first high-performance full-stack open-source bipedal humanoid robot. RP1 is designed for researchers, educators, robotics developers and embodied AI teams, with the goal of providing a humanoid robotics system that can be used, modified, trained and continuously extended in real development workflows.
“Humanoid robots should not be closed systems that only a small number of teams can build while everyone else can do little more than watch,” said Yi Huang, founder of RoboParty.
“We want RP1 to become an open foundation that developers can access, modify, train and continuously improve. Full-stack open source has been our technical direction since the RPO project.”
At RoboParty’s IROS booth, the “Kick Me” interactive demonstration was one of the most direct ways for visitors to experience RP1’s capabilities. During the demonstration, visitors could directly apply external disturbances to the robot. When pushed or kicked, RP1 rapidly adjusted its posture and recovered its balance. Unlike demonstrations based only on predefined motions, this open interaction allowed visitors to observe the robot’s dynamic stability and control performance under external disturbances, according to a press release. The repeated high-intensity interactions also provided a direct test of the robot’s body performance and system-level robustness. RP1’s dynamic motion and disturbance-recovery capabilities at IROS were supported by PartyOS, RoboParty’s open R&D foundation for humanoid robotics, which integrates the UFO framework.
Source link