A robot inspecting an electrical substation cannot afford to miss a fault, just as an autonomous vehicle cannot afford to overlook an unexpected obstacle. Building machines that can operate reliably in such environments requires data, software, testing infrastructure, and hardware that help them interpret the physical world.
Bengaluru-based CaliperAI is developing this infrastructure alongside its own modular robotic platforms.
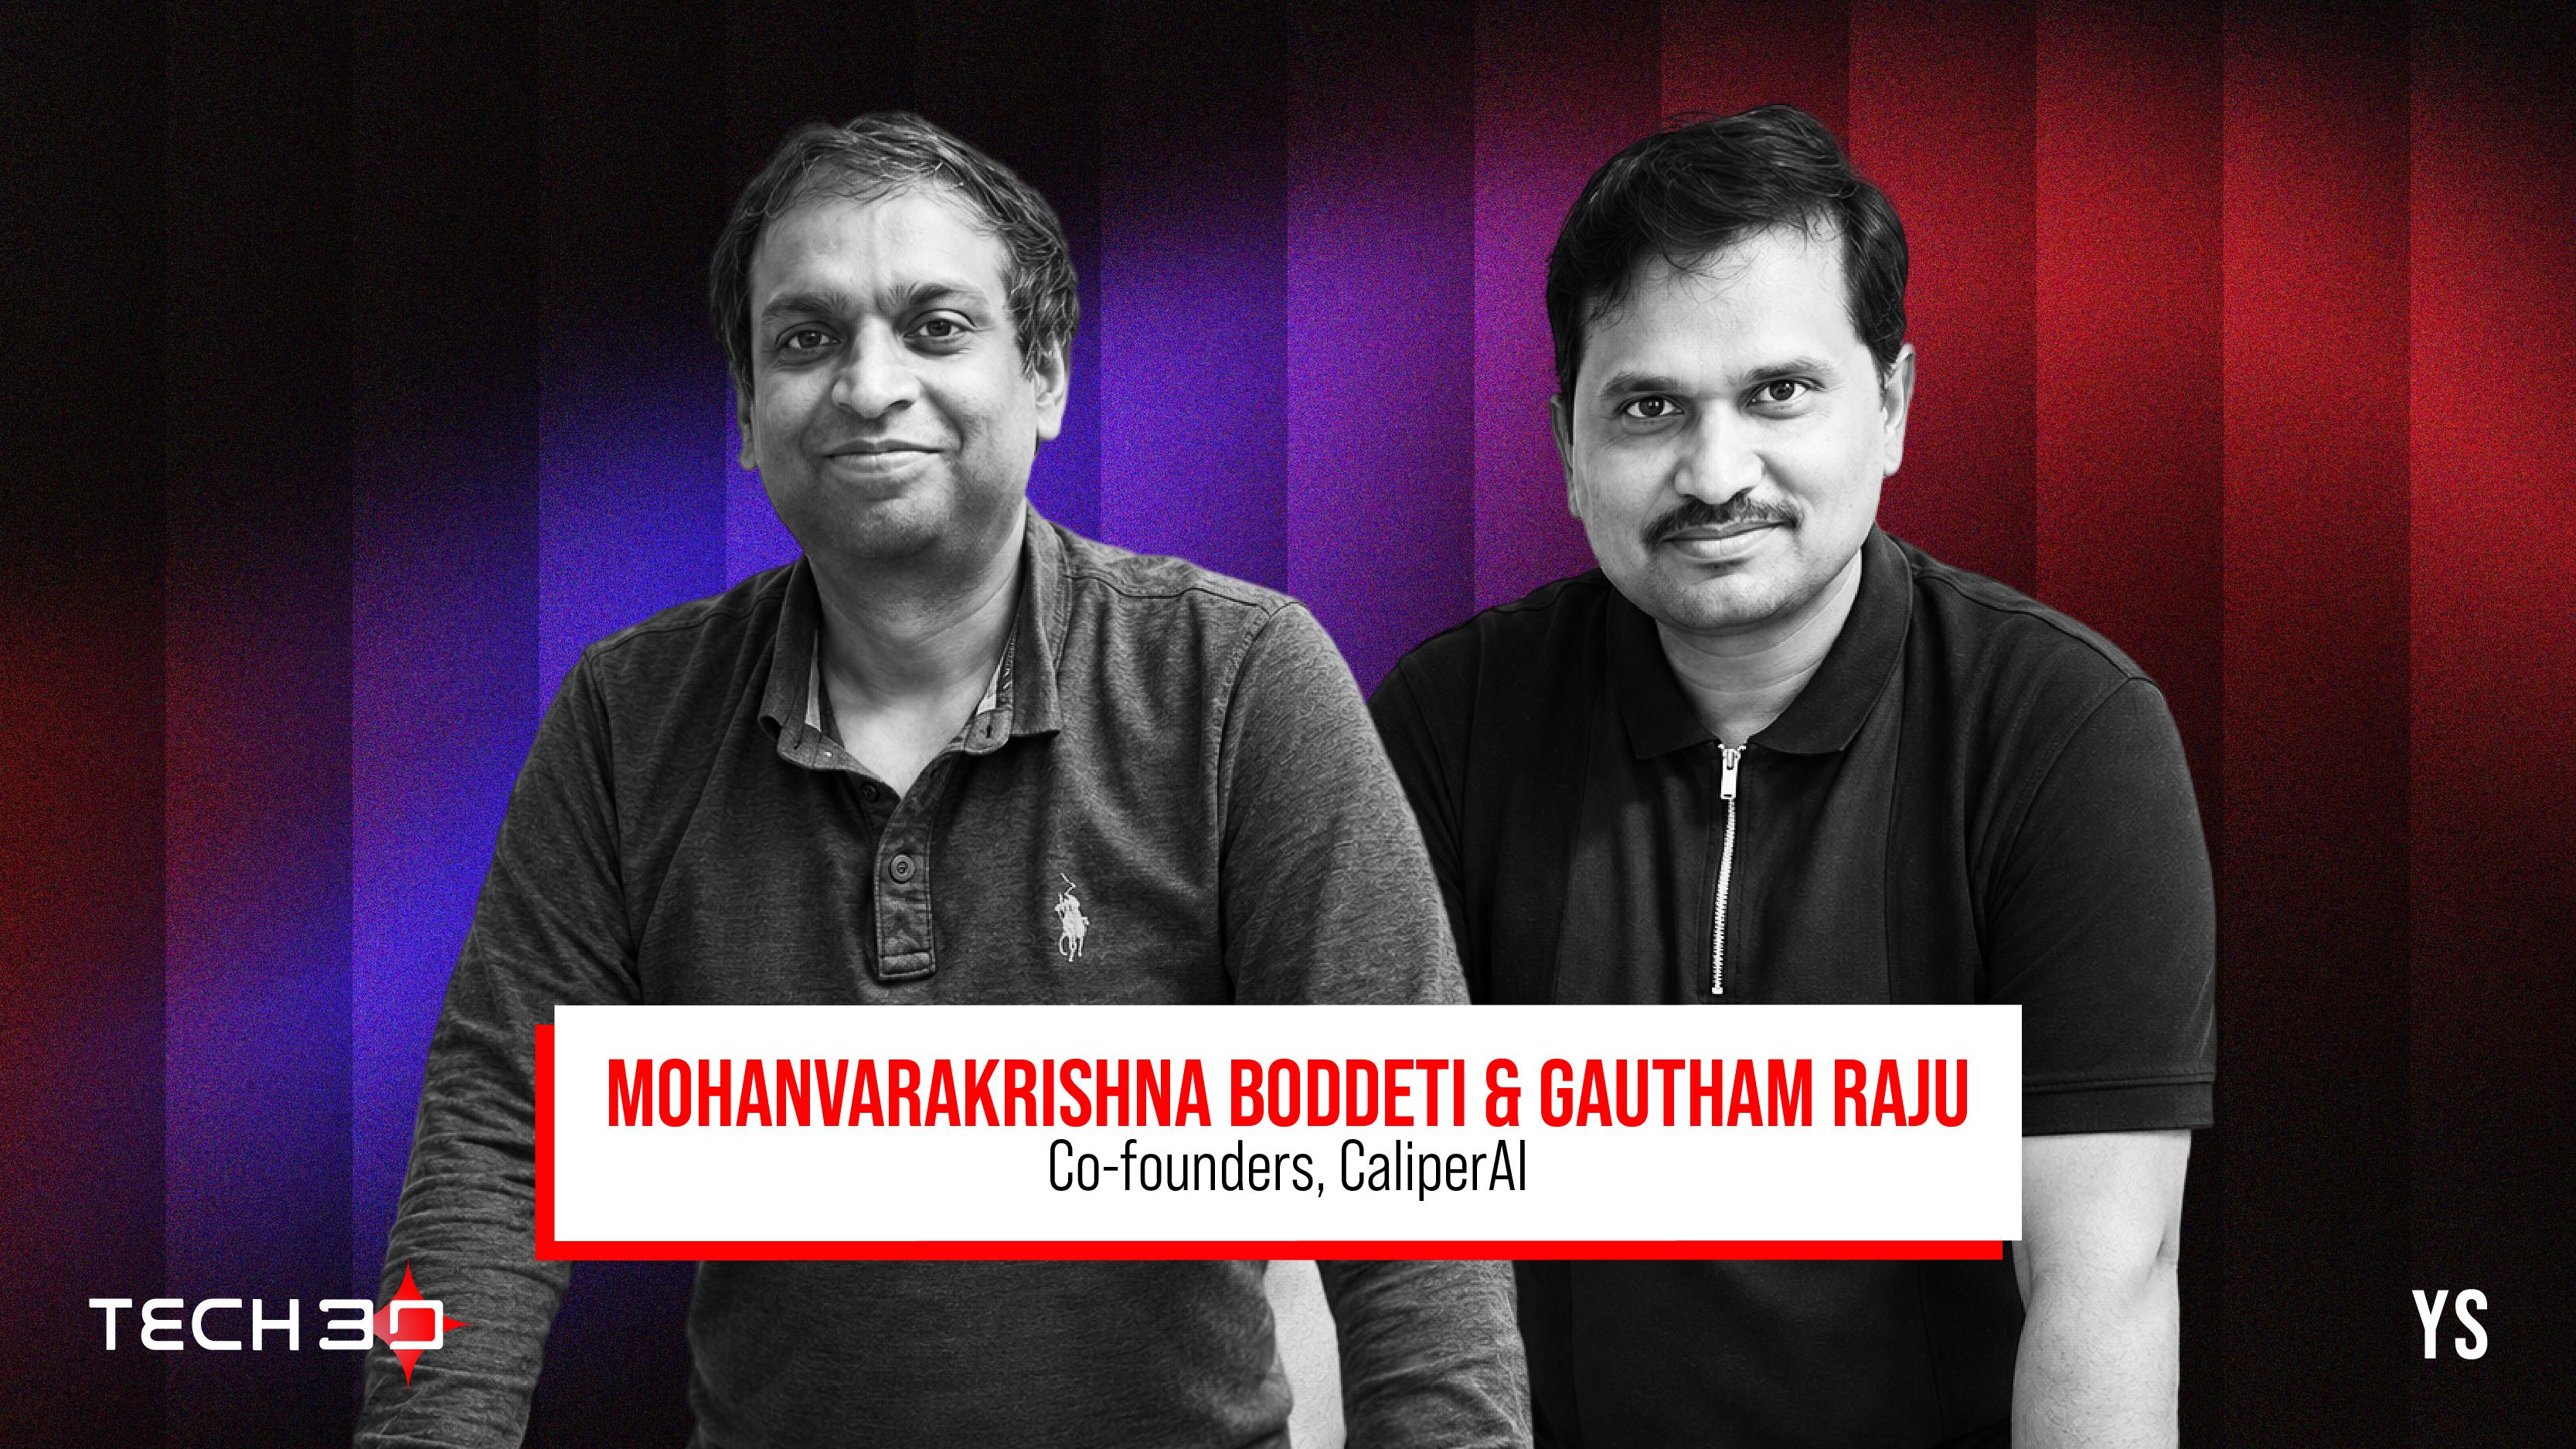
Founded in 2024 by Mohanvarakrishna Boddeti and Gautham Raju, the startup initially focused on gaps in autonomous-driving software development and validation before expanding into physical AI and unmanned ground vehicles (UGVs) for inspecting heavy industrial assets.
The founders spent six to eight months validating the idea before leaving their jobs to work full-time on the startup in May 2025. CaliperAI currently has a team of eight.
“We wanted to develop AI which works as precisely as measuring with calipers,” says Co-founder Gautham Raju. “While AI can go wrong anytime, we want to be extremely precise in the AI we develop."
CaliperAI began by addressing a gap in autonomous-driving development. While tools were available for software development and validation, the founders saw a need for an integrated platform that could support the entire development and release cycle.
“There are software development tools and separate tools to validate it, but not an end-to-end intelligent platform that can cater to the complete development and release cycle,” says Co-founder Mohanvarakrishna Boddeti.
The startup has developed three software tools: CaliperCapture, which collects multimodal sensor data; CaliperOwl, which helps developers understand and organise datasets; and CaliperGT, which generates ground-truth labels used to train AI models.
Source link