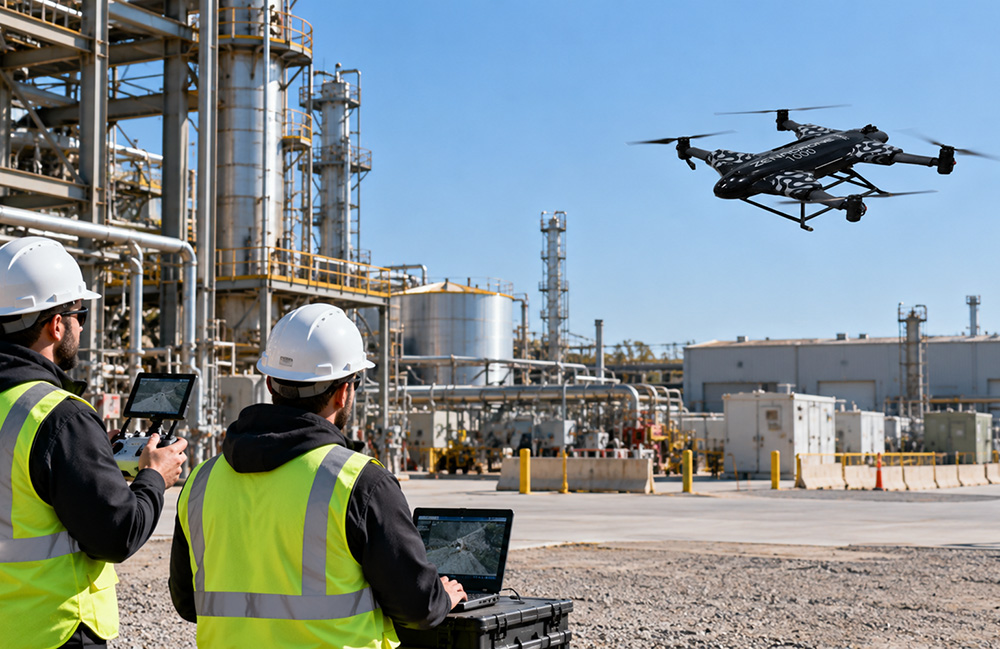
An autonomous drone can complete a carefully planned inspection route in a controlled environment and still struggle with the same route at an operating industrial facility. A steel structure may obstruct satellite signals, reflective equipment may distort depth measurements, and a wind gust may push the aircraft outside its planned trajectory. Each disturbance can be manageable in isolation. The difficulty emerges when several occur simultaneously.
This exposes a fundamental challenge in industrial drone autonomy: performance depends on interactions between subsystems whose assumptions are rarely independent.
A navigation algorithm may estimate position accurately under favorable sensing conditions. An obstacle detector may identify nearby structures during controlled testing. A flight controller may maintain stable tracking under a nominal payload. None of these results independently establishes that the integrated system can safely complete an inspection near energized infrastructure, confined structures, or operating machinery.
Reliable deployment requires engineers to understand how uncertainty propagates through localization, perception, planning, control, and inspection-data acquisition. It also requires evidence that the system can recognize when its estimates are no longer trustworthy.
Industrial facilities introduce environmental conditions that are difficult to reproduce in laboratory demonstrations.
Metallic surfaces, repetitive structural patterns, narrow access corridors, moving equipment, airborne particulates, and changing illumination can affect multiple sensors simultaneously. These conditions create both geometric constraints and uncertainty in the information available to the autonomy system.
As the aircraft approaches the structure, GNSS measurements become less reliable. Repetitive pipes complicate visual feature matching, while reflective surfaces produce inconsistent depth observations. Meanwhile, the flight controller must reject aerodynamic disturbances caused by nearby structures.
Source link