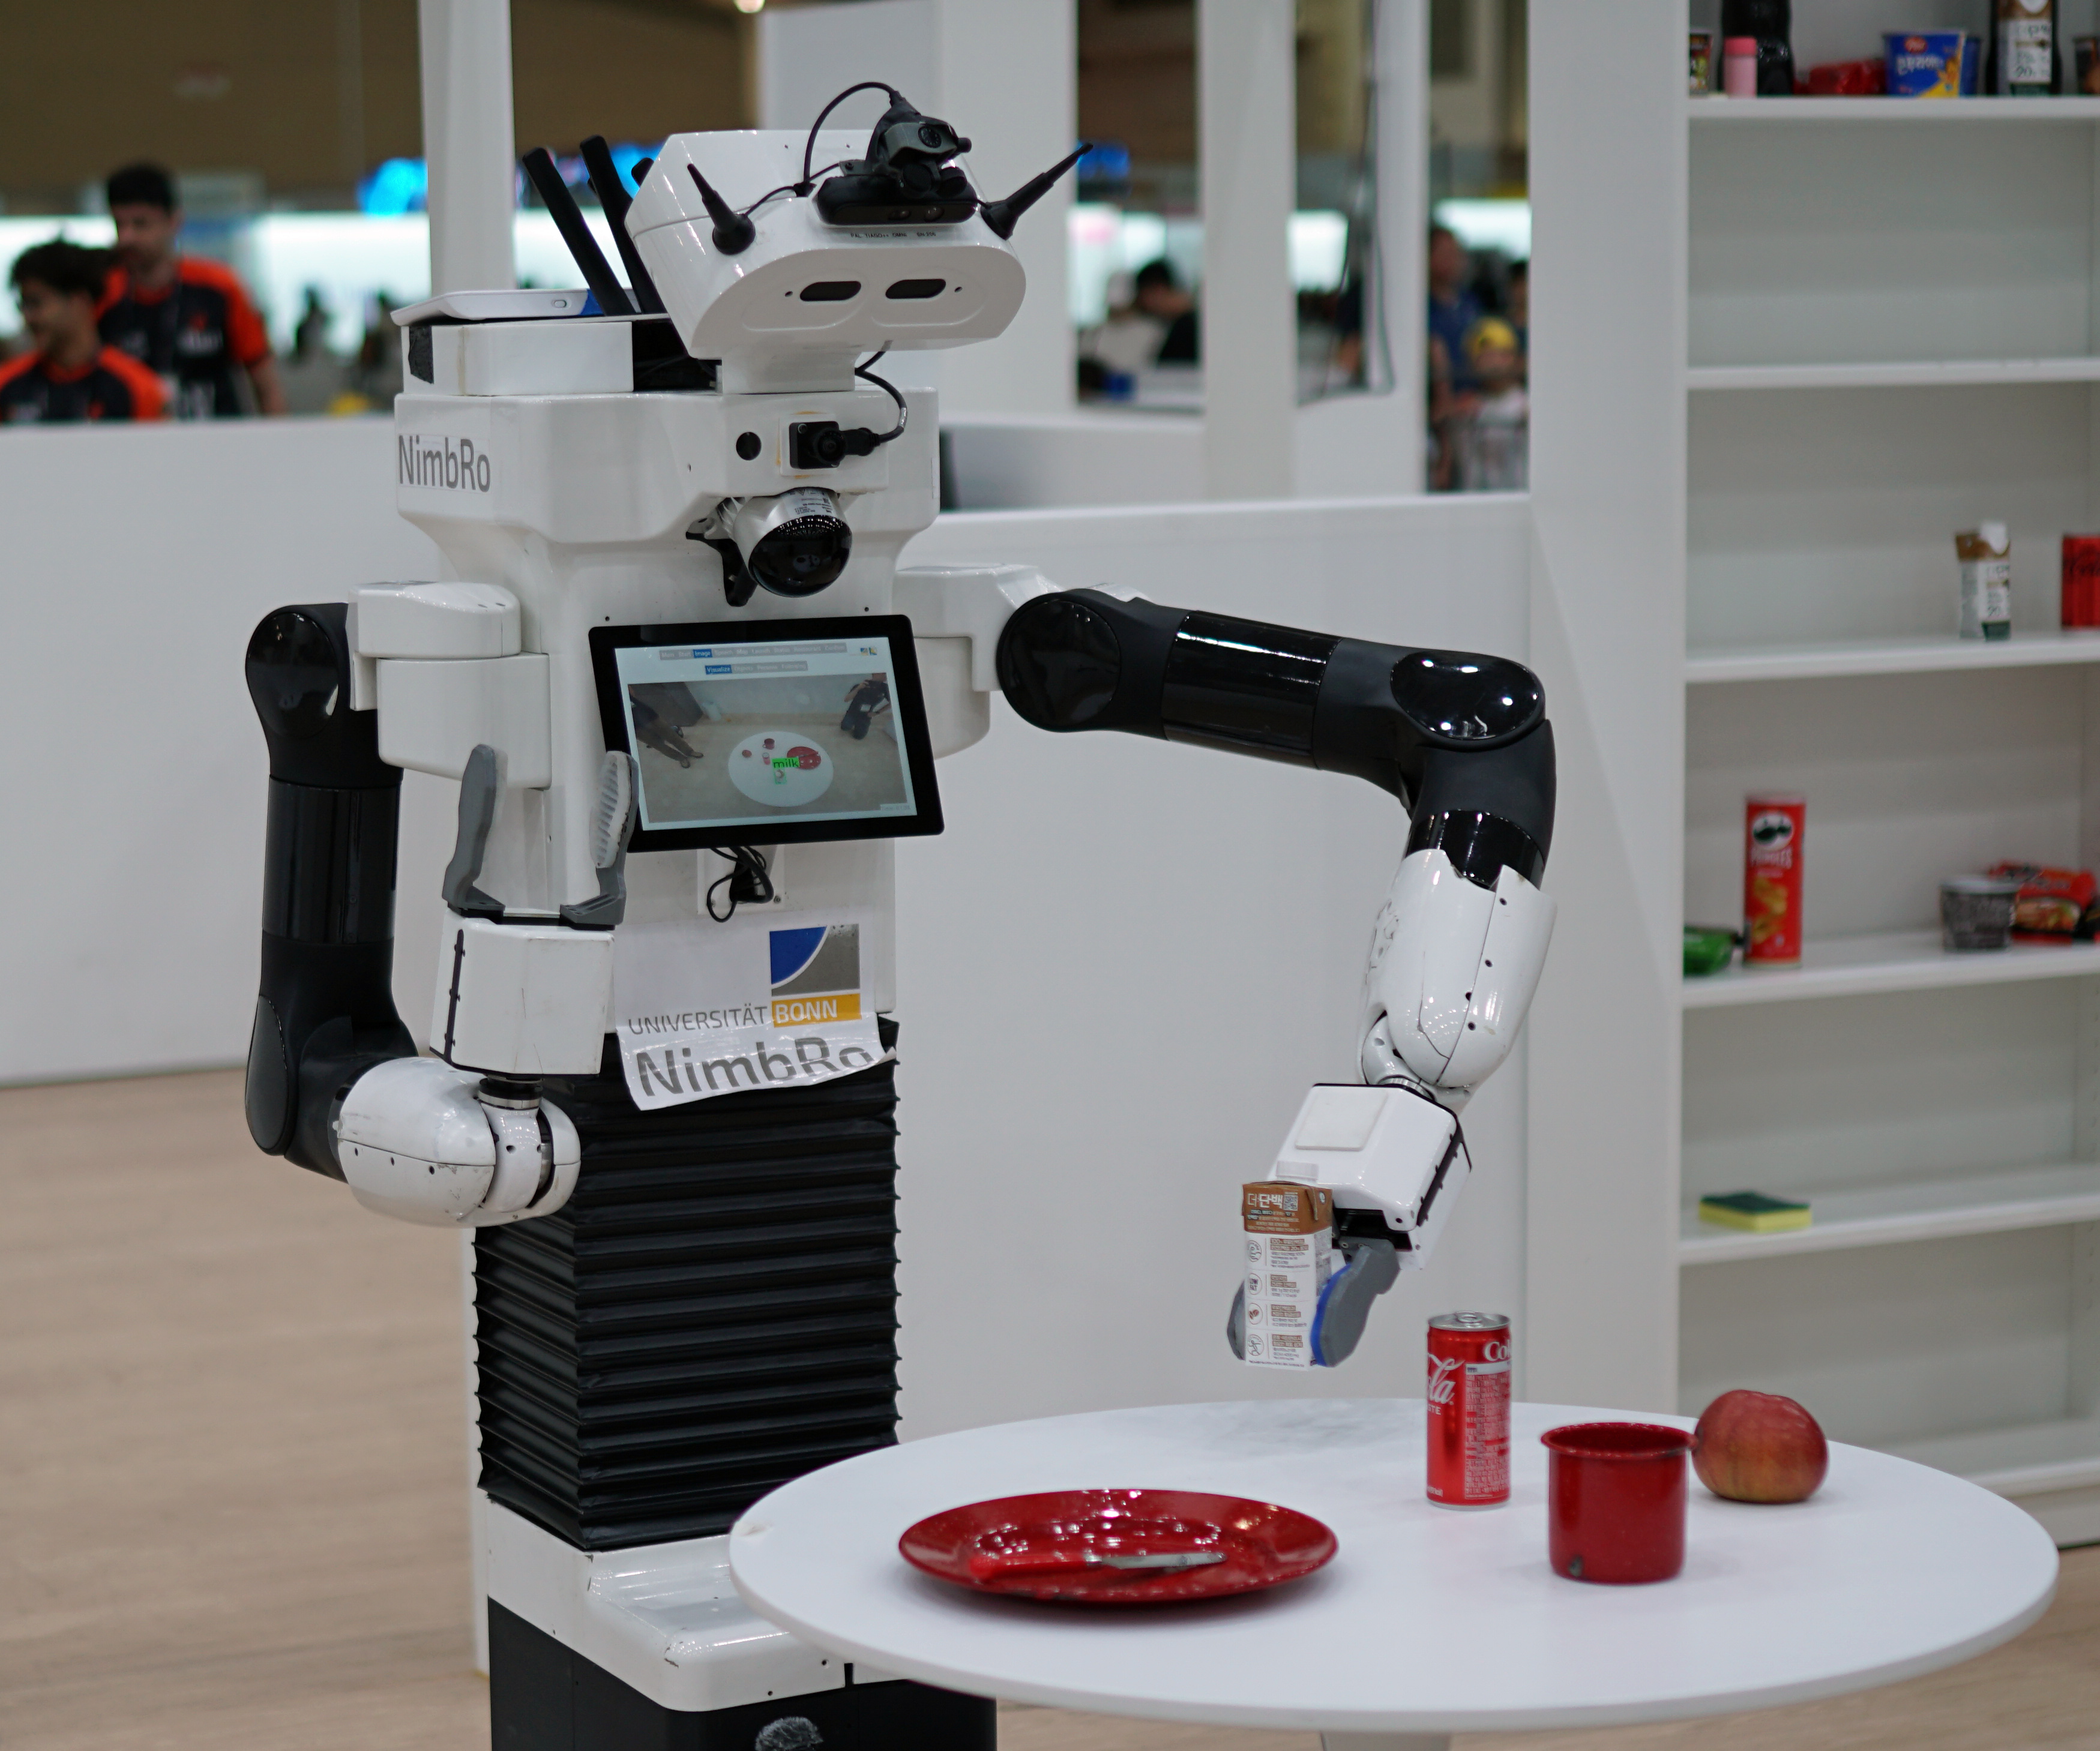
 Team NimbRo’s robot in action during the RoboCup@Home competition at RoboCup 2026. Raphael leads the team.
Raphael Memmesheimer has been successfully competing in the RoboCup@Home league winning the RoboCup@Home competition five times. He and his colleagues won the best paper award at RoboCup 2026 for their work “Efficient Image Annotation via Semi-Supervised Object Segmentation with Label Propagation”. We caught up with Raphael to find out more about this research, his history with RoboCup, and the challenges of the @Home competition.
I’ve actually been involved in the @Home league since I was a student, and my first time going to a World Cup for @Home was in 2013. That competition motivated me to do a PhD and infected me in a way that meant I basically aligned my academic career to it. I always return to robot competitions because this is one of the rare places where you can benchmark robots in a real environment and have a real competition. Commonly in research you tune your approaches on data sets and show that they perform in a one-shot video. In robot competitions, you basically have to roll out your robot, it enters the arena, and then it operates autonomously on its own. It is always interesting to see how new developments make the robots perform better.
The motivation for this work is that we only have two preparation days at the RoboCup competitions. So we arrive there, we have to assemble our robots, and the robots need to get used to the new environment [a model apartment] that we haven’t seen before.
Source link