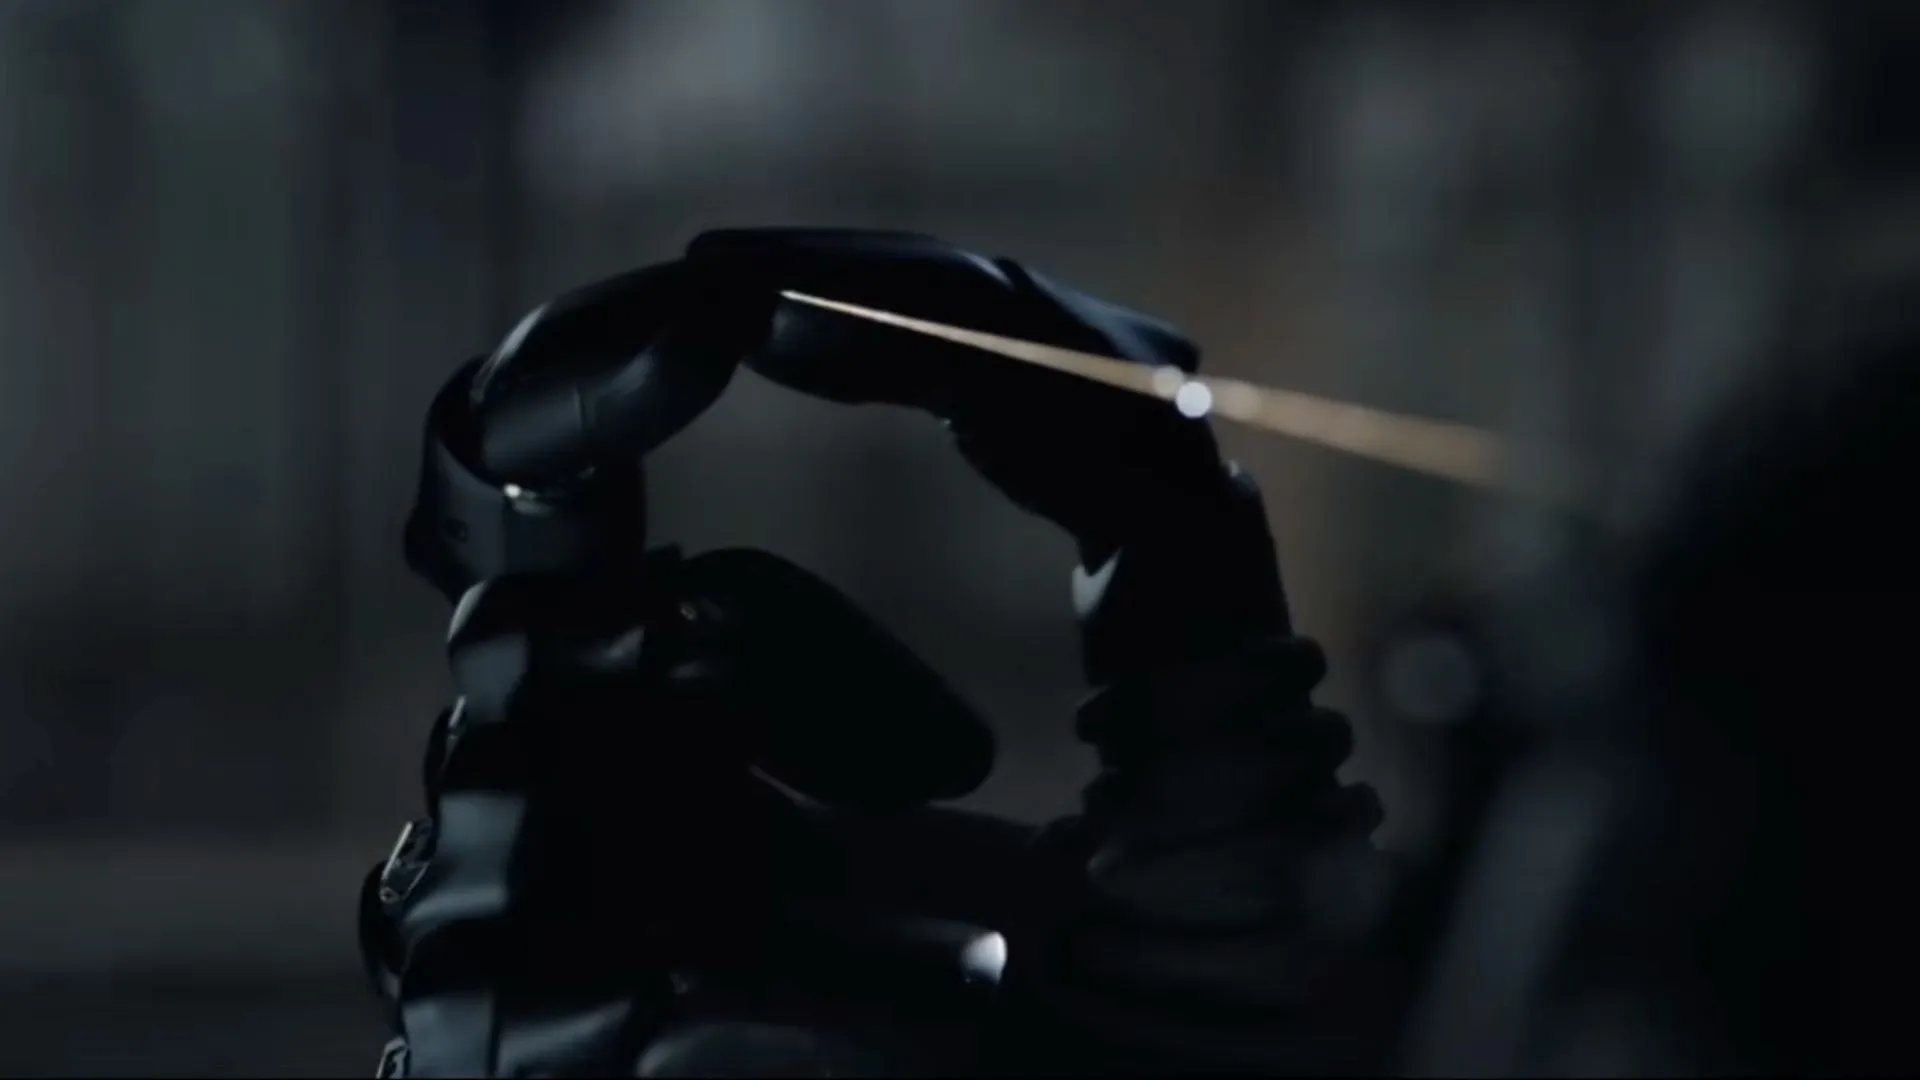
Chinese robotics startup AGILINK has demonstrated its robot hand performing basic embroidery techniques using silk thread. The demonstration involved separating a silk thread into 16 finer strands, threading a needle, stretching fabric across a hoop, and making initial stitches.
The firm’s OmniHand 3 Ultra robot hand used coordinated finger movements to maintain tension while separating and handling the delicate strands.
The demonstration highlights the challenges of using robotic hands for precisely manipulate thin, flexible materials.
AGILINK, a spin-off of Chinese robotics company AgiBot, has demonstrated its OmniHand 3 Ultra dexterous robot hand performing techniques used in traditional Suzhou embroidery. The demonstration involved training the robotic hand to split silk thread, thread a needle, stretch fabric across an embroidery frame, twist thread, and make stitches.
Suzhou embroidery requires precise handling of silk, which can bend, slip, and change shape under small changes in applied force. In the demonstration, embroidery master Fu Xianghong taught the robot how to manipulate the material—one of the key steps involved separating a main silk thread into 16 finer strands. The robot used one finger to separate the strands while its other fingers maintained tension.
The hand also had to keep its fingertips in contact with the silk while allowing the thread to rotate during twisting. Threading the needle and stitching required additional control over position, force, and finger coordination.
“Silk has no rigid shape. The force of the fingers decides it. That makes embroidery a test of hardware and control together: a fully direct-drive hand with 21 active degrees of freedom, and a visual-tactile sensor in every fingertip that reads contact from surface deformation,” reads the video description posted by the firm.
Source link