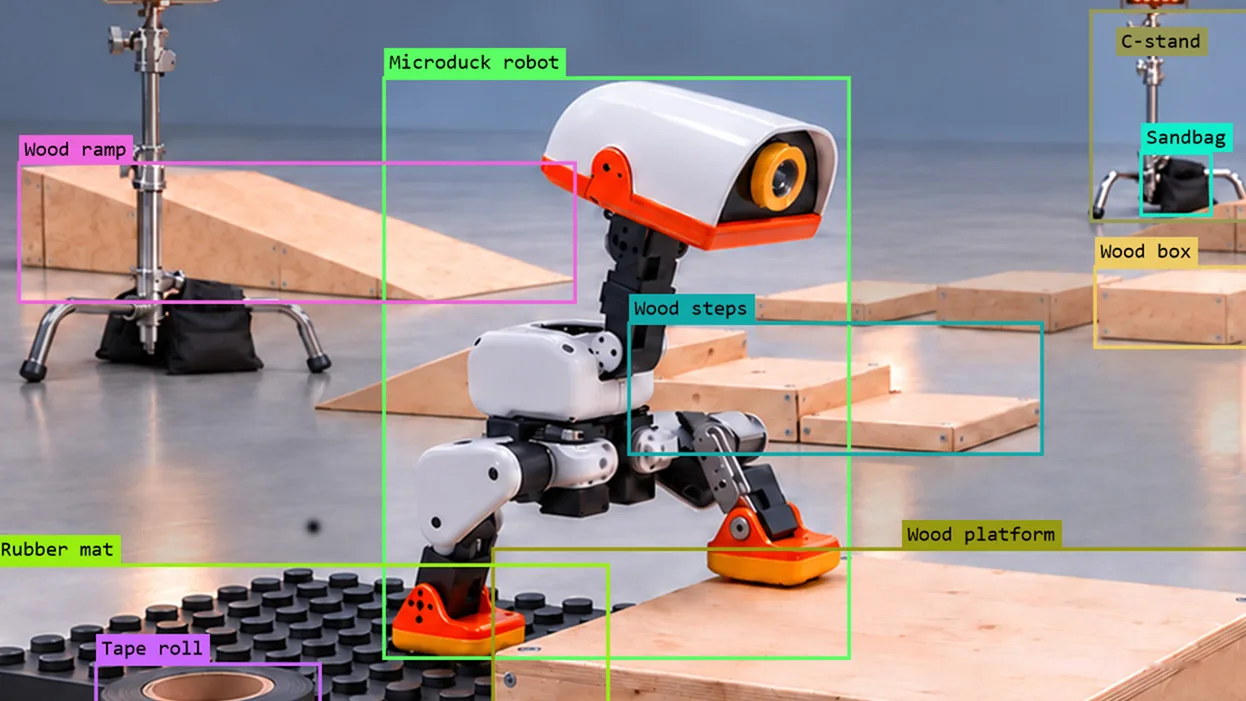
Teaching a robot to navigate an obstacle course requires more than a walking policy. It must perceive its surroundings, maintain balance, and adjust its actions... Teaching a robot to navigate an obstacle course requires more than a walking policy. It must perceive its surroundings, maintain balance, and adjust its actions when obstacles block the path ahead. Developing these capabilities connects several stages: creating assets and an environment, using physics simulation to model how the robot interacts with its environment, and training and evaluating…
Source link