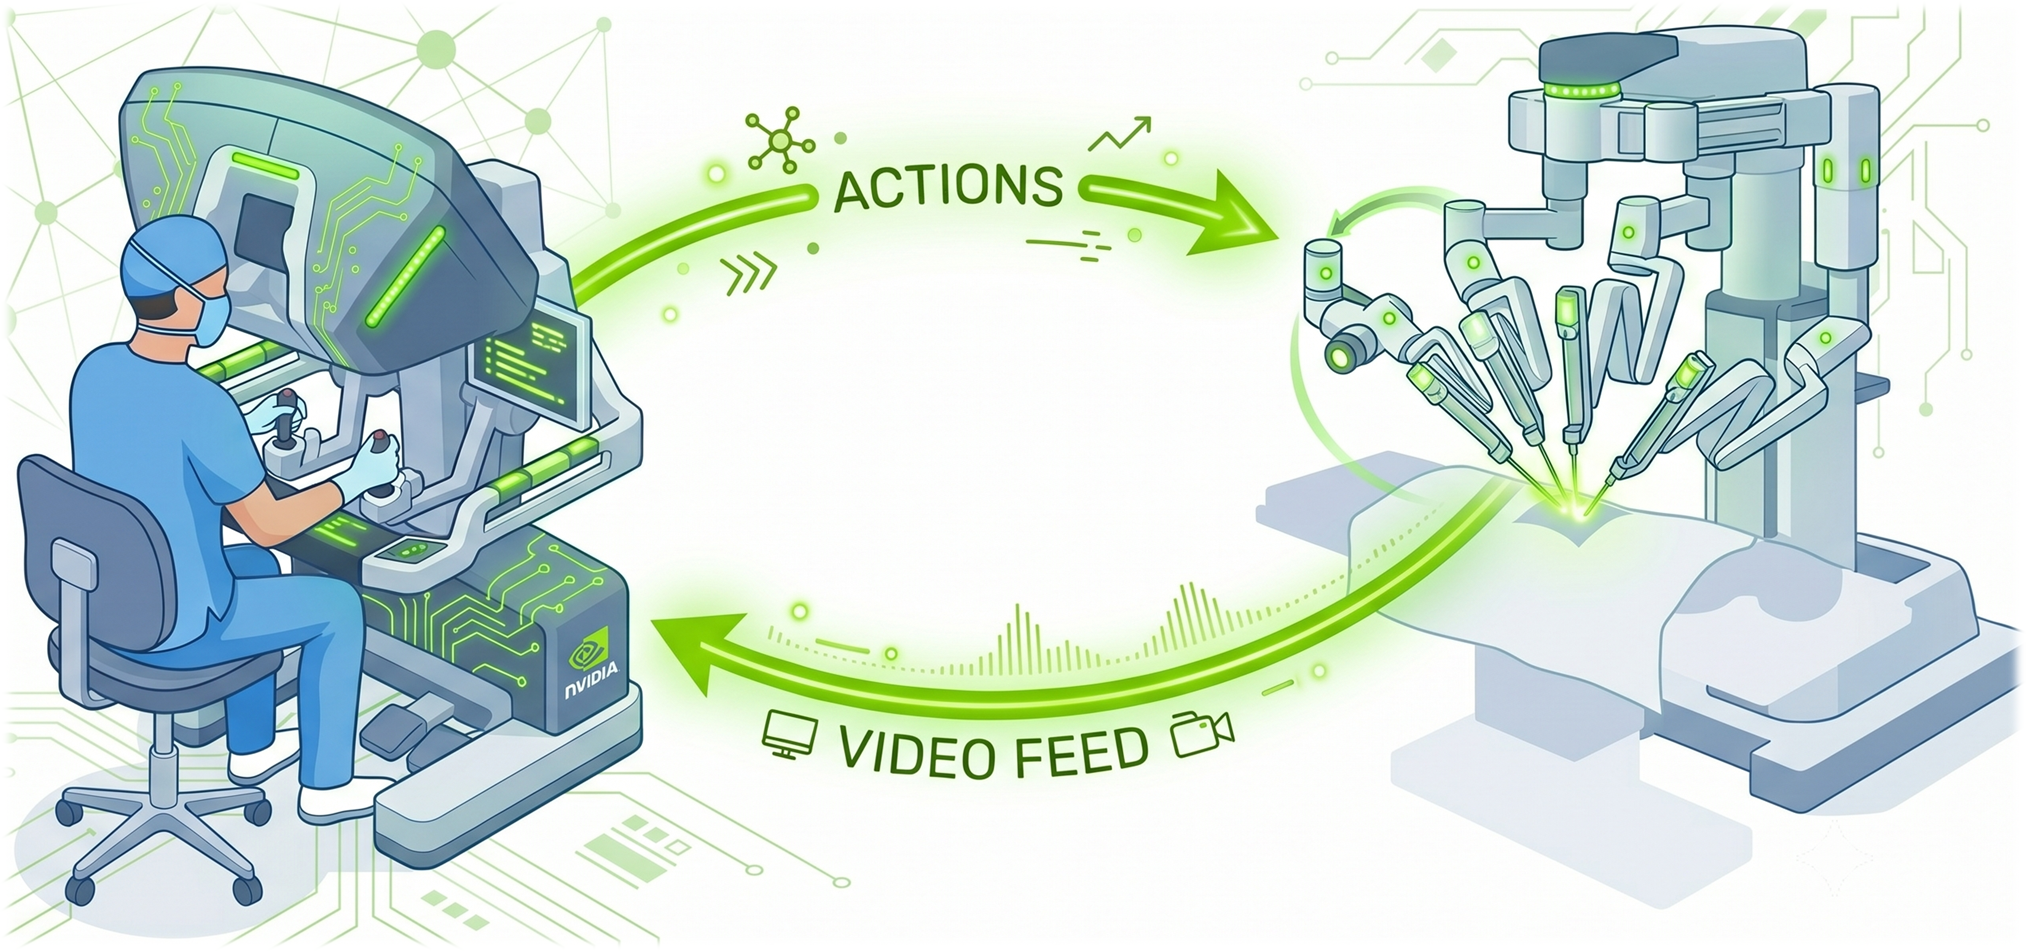
Our first Cosmos-H-Dreams release, built on Cosmos-Predict2.5, brought interactive generative simulation to dVRK tabletop suturing, a foundational proving ground for surgical robotics. As world foundation model (WFM), Cosmos-H-Dreams demonstrated an alternative to numerical simulation: rather than explicitly modeling scene geometry, tissue deformation, and physical interactions, it learned visual dynamics directly from synchronized video and robot kinematics, yielding interactive tabletop task simulation with high realism.
Today, Cosmos3-H-Dreams advances this capability by learning from video and robot kinematics recording during clinical procedures on the CMR Surgical Versius platform. To our knowledge, this is the first real-time generative surgical simulator trained on clinical cholecystectomy recordings to support live kinematic control. Powered by Cosmos 3 and accelerated with FlashDreams, NVIDIA’s accelerated streaming-inference library, Cosmos3-H-Dreams runs interactively on a single NVIDIA RTX PRO 6000 GPU.
In a controlled tabletop environment like that of Cosmos-H-Dreams, instruments operate against a relatively simple background.
Source link